The robot arm
A clean Python library for the Dobot Magician, a camera, and a screen. The library is on PyPI. The point is a large world model.
The library
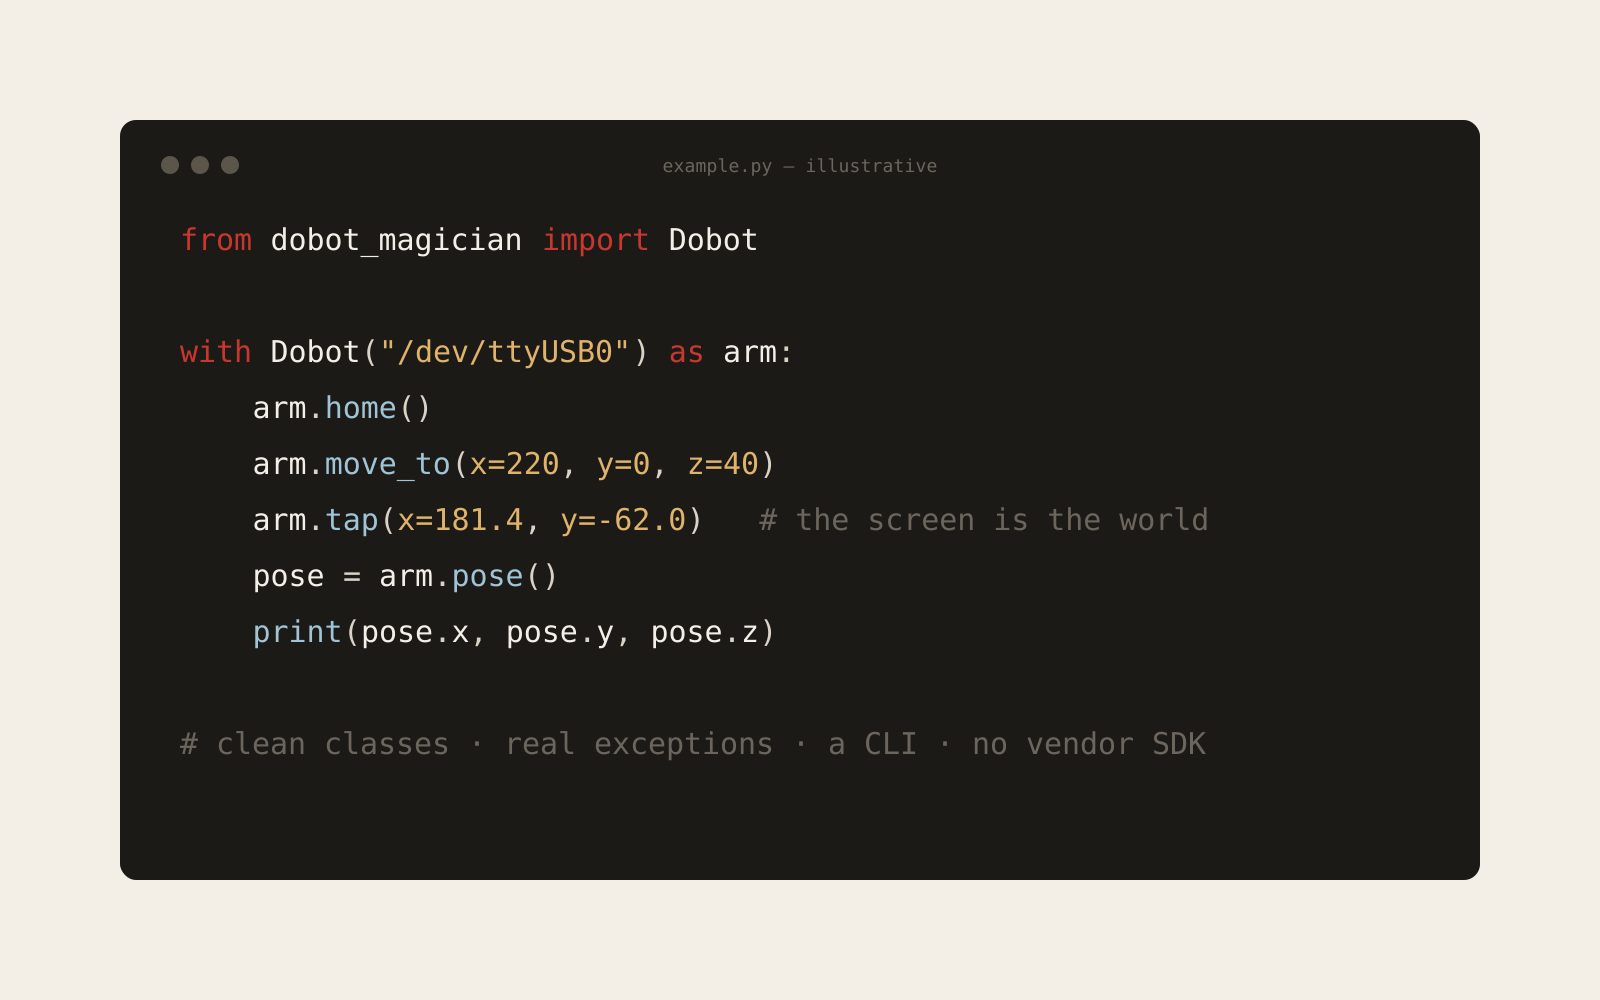
It started because the official SDK for the Dobot Magician made me sad. So I wrote a clean one: proper class separation, real exceptions, a CLI, no vendor weirdness. It's published to PyPI.
The rig
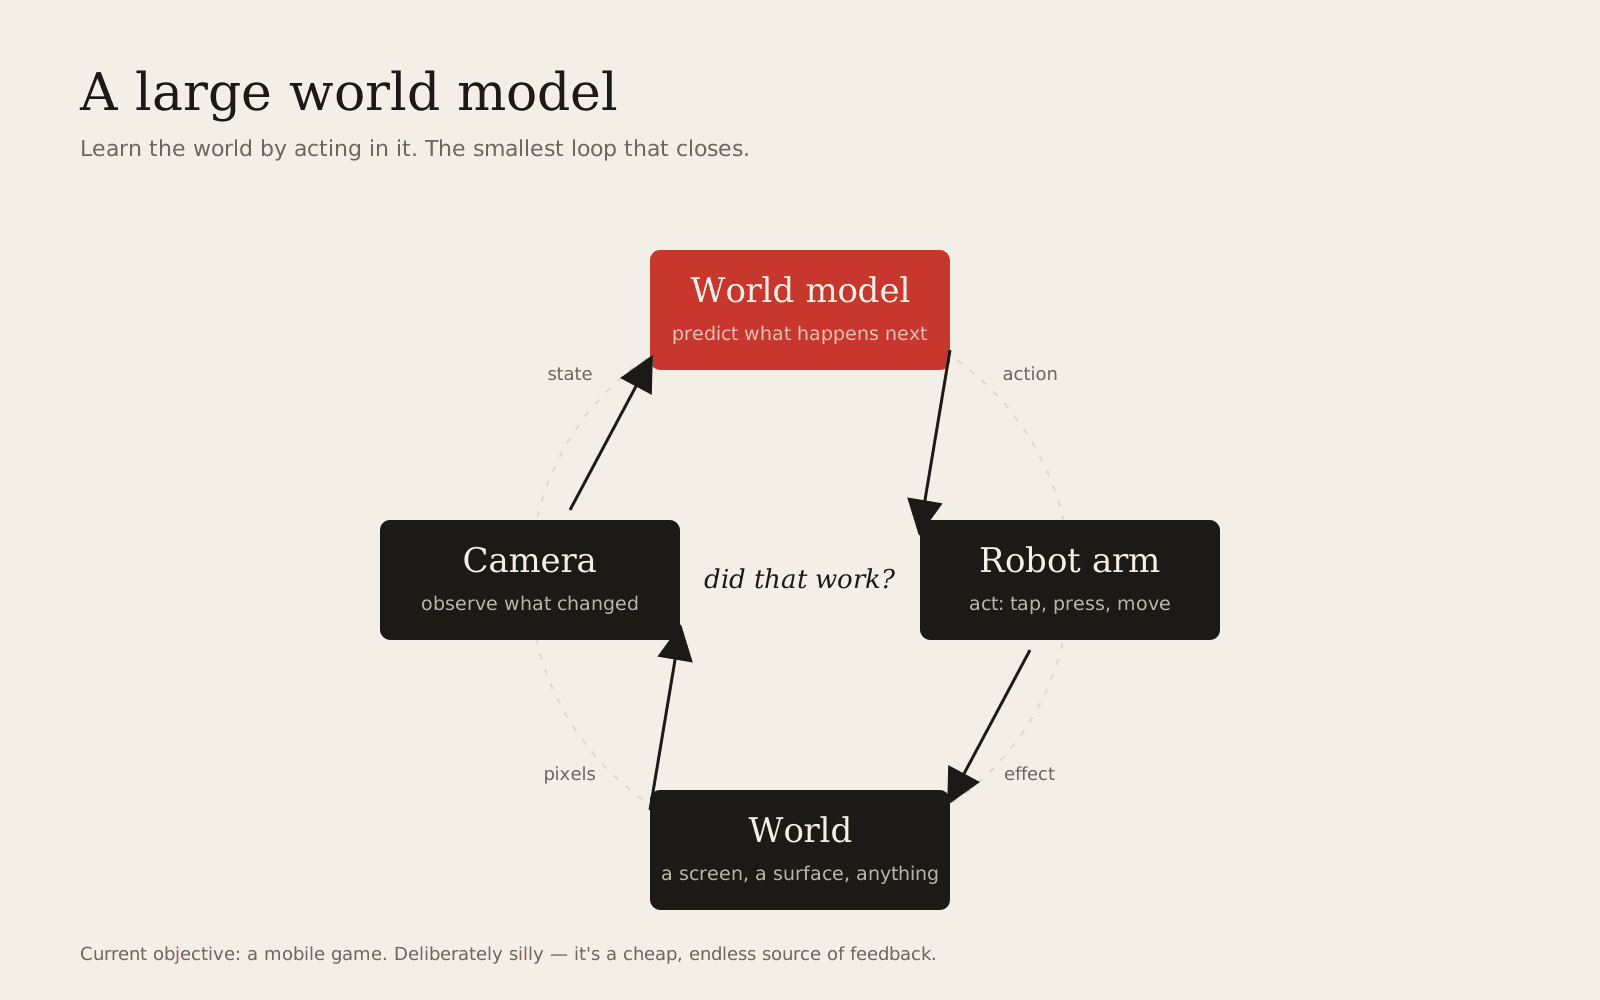
Arm, camera, screen. The camera watches the screen, a vision model decides what to do, the arm does it, the camera watches what changed. The smallest loop I could build that actually closes.
The real goal: a large world model
Large language models learned from text. The interesting question is what a model learns when it has to act — see something, do something, see what changed, and try again. That's what the rig is for. The current objective — playing a mobile game on an iPad — is deliberately silly: a cheap, endless source of "did that work?" signals. The goal is the model, not the game.